edge-detection
6 posts · browse all tags
 Fundamentals
Canny: Non-Maximum Suppression and Hysteresis, Taken Apart
Lesson 4 of the Edge Detection unit. Canny is two independent mechanisms, not one tuned number. NMS collapses a five-pixel ridge to one pixel by comparing along the gradient; hysteresis keeps a weak chain because it touches a strong seed. Worked on nine numbers: a single threshold gives either 1 pixel or 9, and hysteresis gives the 6 that belong to a real contour. Measured on a photo, that is 204 contours averaging 18.68 px against 393 averaging 9.69 px at the same pixel budget.
 Fundamentals
Corners: The Structure Tensor, Harris, Shi-Tomasi and Förstner
Lesson 5 of the Edge Detection unit. A contour says where a boundary runs but not where you are along it. Two eigenvalues of a 2x2 matrix fix that: measured on a real photo, flat background scores 0.001/0.000, an edge 0.411/0.019 and a corner 0.442/0.318. Harris, Shi-Tomasi and Förstner all read that same matrix, and on the edge patch Harris comes out positive at k = 0.04 and negative at k = 0.06, so k decides the answer rather than the data.
 Fundamentals
Edge Detection: Finding Where One Thing Stops and Another Begins
The unit overview: what counts as an edge, the two derivatives that find one, why a single threshold never works, and how contours become the points a matcher can use. Measured on one photo: smoothing across rows recovers 80% of the clean edge set at noise σ=20 against 63% without it, and hysteresis returns contours twice as long as a single threshold at the same pixel budget.
 Fundamentals
Image Gradients: Central Differences, Prewitt and Sobel
Lesson 2 of the Edge Detection unit. Three operators compute the same derivative and behave differently on a noisy photo. Worked by hand on a 3x3 patch: Sobel gives Gx = Gy = 1.80, a magnitude of 2.55 and an orientation of 45 degrees, while Prewitt gives 1.20 and 1.70 on identical pixels. Measured across a noise sweep, Prewitt beats Sobel at every level, and the reason is that its normalised weights have a smaller sum of squares.
 Fundamentals
The Laplacian, LoG and Zero-Crossings
Lesson 3 of the Edge Detection unit. The second derivative crosses zero at an edge instead of peaking, which locates a step edge at exactly x = 3.5 from integer pixels. It also has no smoothing in it: nine pixels disturbed by 0.03 produce four sign changes where there should be one. Measured on a photo, noise multiplies the zero-crossing pixels by 2.76x at sigma = 1.0 and 1.02x at sigma = 3.0, and only 33% of the resulting contours are closed.
 Fundamentals
What Is an Edge? Step, Ramp and Roof, and the Two Derivatives That Find Them
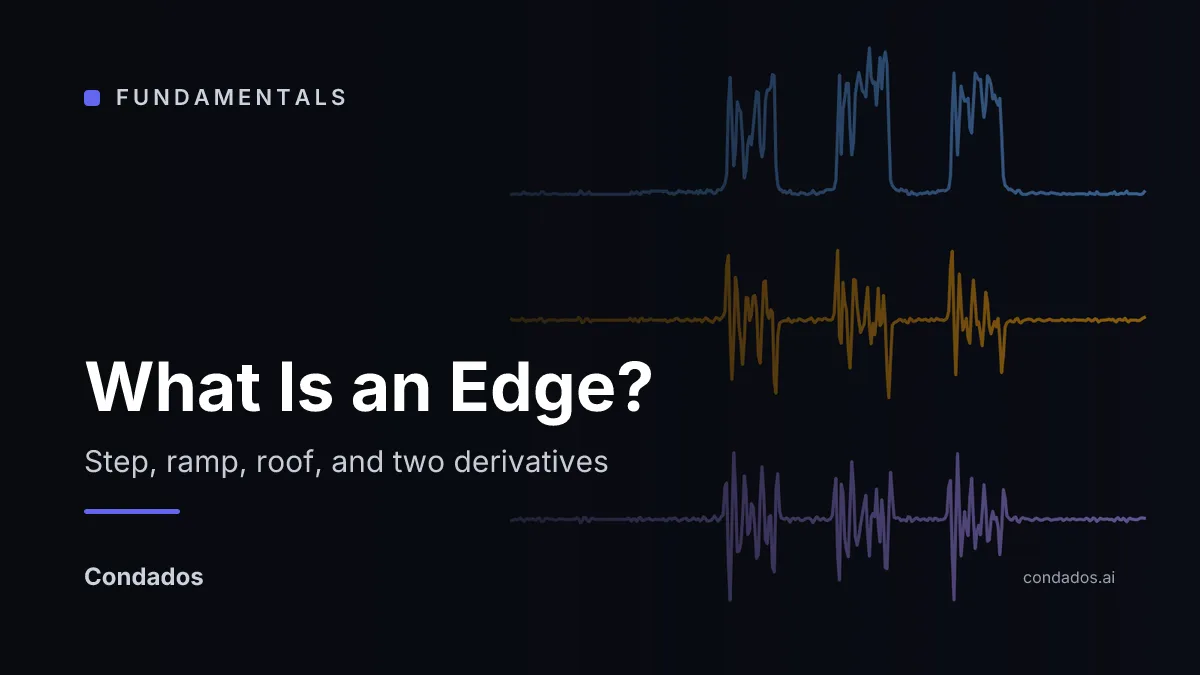
Lesson 1 of the Edge Detection unit. An edge is a peak in the first derivative and a sign change in the second. Worked by hand on nine pixels: the peak lands on column 4 and the second difference is exactly zero there. Add plus-or-minus 0.03 of noise and the first derivative holds its position while the zero-crossing slides half a pixel off the edge, which is why Canny is built on the first derivative and not the second.