camera-calibration
6 posts · browse all tags
 Fundamentals
Image Formation: How a Camera Flattens the World Onto a Sensor
The unit overview: why a pinhole gives a sharp picture and a lens gives a bright one, what focus costs you, and where the pinhole model stops describing the lens in front of you. Measured on public photographs: a real lens moves a corner 51 px, stopping down from f/4 to f/22 deepens focus 5.54x, and a fisheye fitted with the wrong model misses by 7.3 px against 0.64 px with the right one.
 Fundamentals
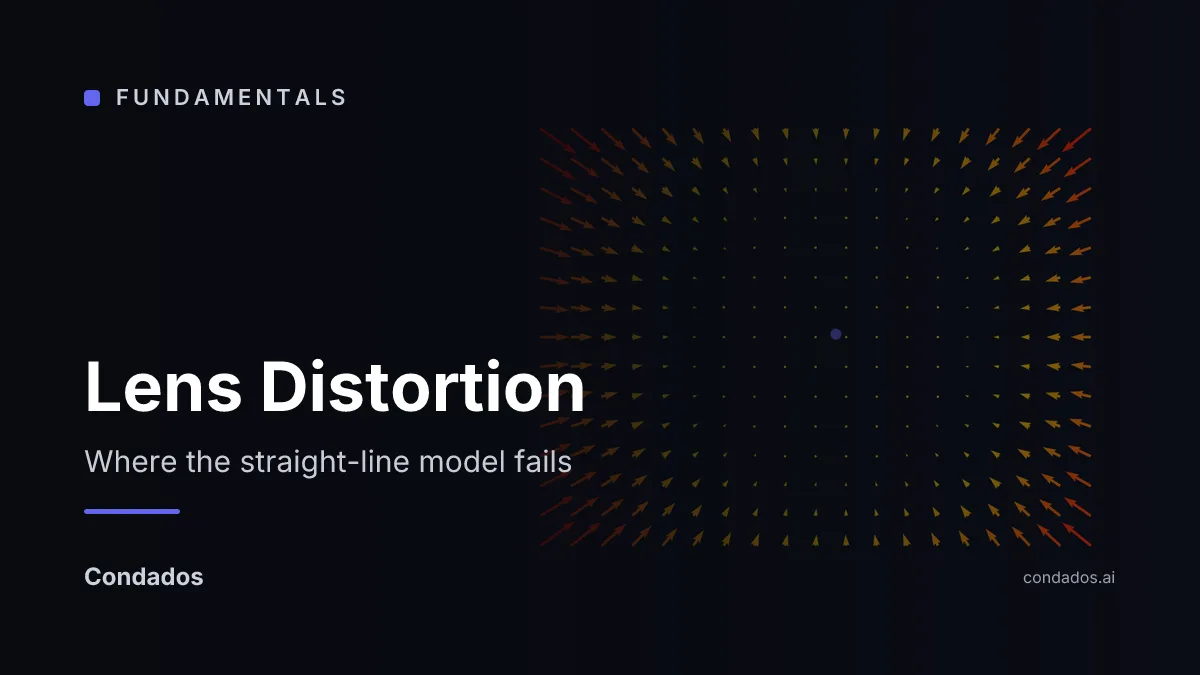
Lens Distortion: Where the Straight-Line Model Actually Fails
Lesson 3 of the Image Formation unit. Real glass bends rays more at the edges, and the error grows with the sixth power of radius. Measured on OpenCV's calibration set: the top-left pixel of a 640x480 frame belongs 51.22 px from where the pinhole model puts it, and adding the Brown-Conrady terms drops the mean reprojection error of one view from 2.55 px to 0.170 px. Straightening it back costs field of view rather than pixels: 61.67 degrees becomes 67.32.
 Fundamentals
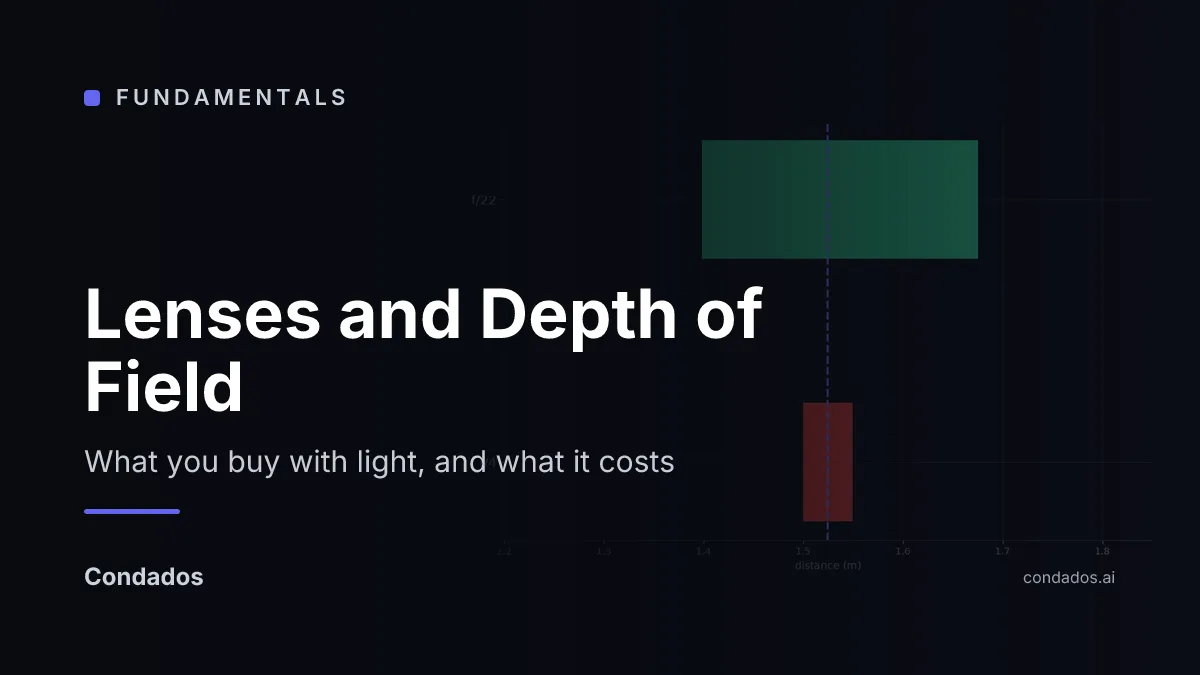
Lenses and Depth of Field: What You Buy With Light, and What It Costs
Lesson 2 of the Image Formation unit. A lens buys the brightness a pinhole cannot have and charges a plane of focus for it. Worked on a published scene: 93 mm at f/4 focused at 1.52 m is sharp from 1.500 m to 1.550 m, a band 5 cm deep. Stopping down to f/22 widens it to 0.277 m, a factor of 5.54 against an aperture ratio of 5.50, and the circle of confusion behind those numbers comes out at 0.0248 mm.
 Fundamentals
The Pinhole Model: Why a Hole Makes a Picture, and Where the Prediction Fails
Lesson 1 of the Image Formation unit. A pinhole projects a scene point to a pixel by similar triangles, and that is a prediction you can check. Worked on one board corner from OpenCV's calibration set: the model puts it at (523.98, 77.94) and the detector found it at (513.77, 86.53), 13.34 px apart. Across the view the error is 0.29 px in the middle third of the frame and 5.75 px in the outer third, which is the shape of the problem the rest of the unit solves.
 Fundamentals
Fisheye Models: When Correcting the Lens Stops Working
Lesson 4 of the Image Formation unit. Past roughly 120 degrees the pinhole model is not inaccurate, it is the wrong shape, because tan θ runs to infinity while the sensor does not. Fitted to the same 15 photographs of one fisheye lens, pinhole plus Brown-Conrady reaches 7.326 px RMS and Kannala-Brandt reaches 0.644 px. At 80 degrees the first model predicts a radius of -35,572 px, a sign flip; the second predicts 458.8 px, which is on the sensor.
 Fundamentals
Camera Models, End to End: K, the Extrinsics, Calibration & PnP, with OpenCV
How a 3-D point becomes a pixel and back again: the intrinsic matrix K, the extrinsics R|t that place the camera in the world, Zhang calibration to 0.35 px reprojection error, and solvePnP recovering a 68-px-off pose to ~0. The math, two interactive labs, and runnable OpenCV in Python and C++.