1 post · browse all tags
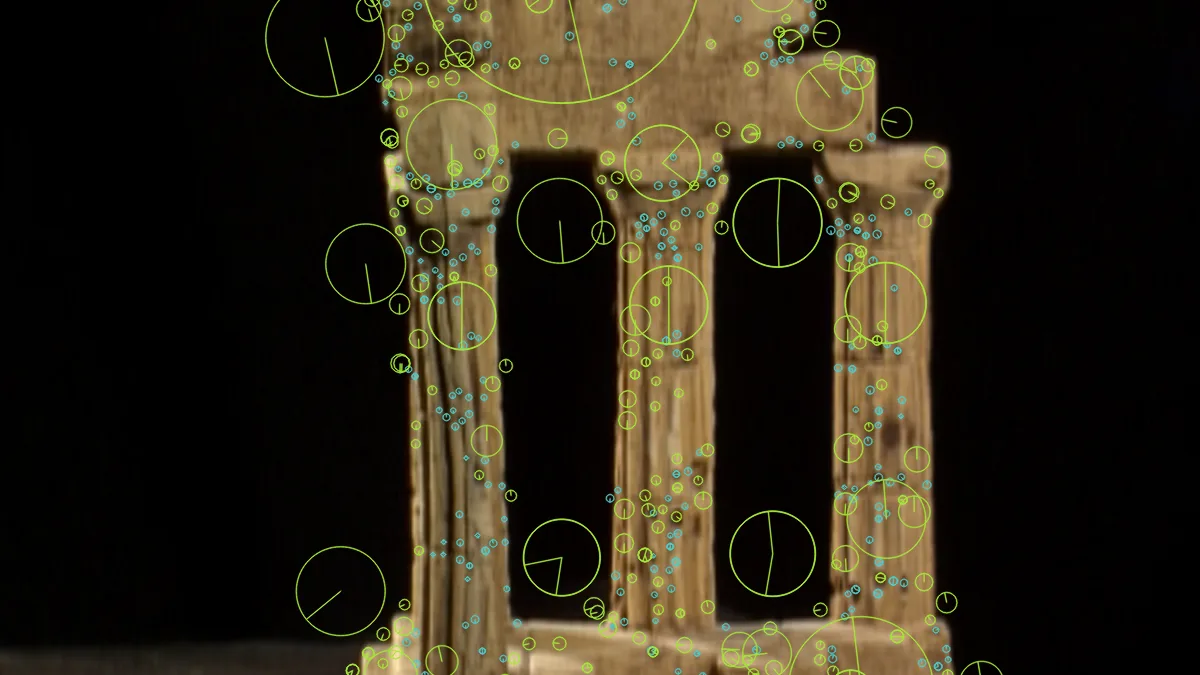
How SIFT turns a patch of pixels into 128 numbers that survive a moving camera. Measured on a real photo: a 45-level difference-of-Gaussians pyramid finds 791 keypoints spanning 1.8 to 112 px, each becomes a 128-dimensional descriptor, and Lowe's ratio test turns 791 candidates into 237 trustworthy matches. The invariances are real but bounded: 98.8% precision through a 45° rotation, and the scene is lost by 38° of viewpoint change. Every number has an artifact.