1 post · browse all tags
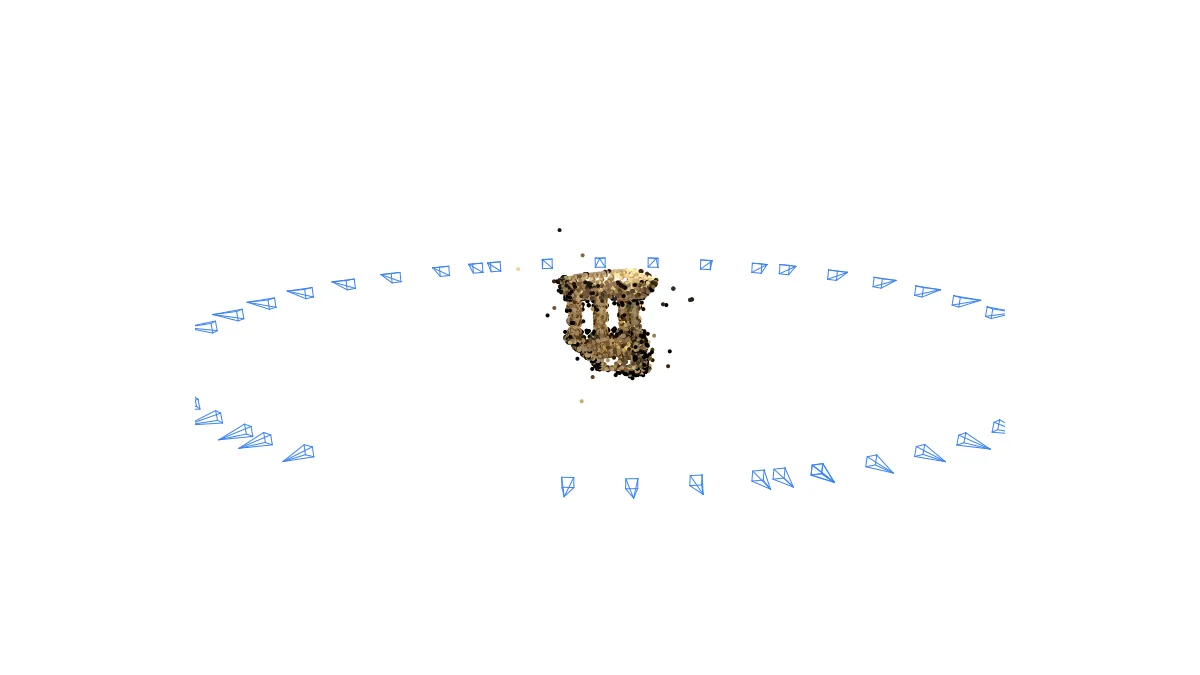
How overlapping 2-D photos become 3-D points and camera poses: SIFT matching, the essential matrix, triangulation, PnP growth, and sparse bundle adjustment, built from scratch with OpenCV + SciPy. The pipeline registers all 47 Middlebury temple views at 0.25 px mean reprojection error, next to COLMAP's 0.30 px on the same images. Worked examples, three interactive labs, and the reconstruction growing image by image.